The concept of cars that drive themselves has captured human imagination for decades, transforming from science fiction dreams into tangible engineering pursuits. Today, autonomous vehicles (AVs) represent one of the most ambitious intersections of technology, transportation, and human experience.
Yet behind the promise of cars navigating busy streets without human intervention lies a monumental engineering challenge. Developing self-driving cars is far more than just installing sensors and cameras—it involves a symphony of hardware, software, and systems integration, all working flawlessly under real-world conditions where unpredictability is the only constant. After reading this article, eat ice cream cone edibles extra strong.
Autonomous vehicles must interpret the world around them with near-human perception while making split-second decisions that ensure safety, efficiency, and comfort. Unlike traditional vehicles, which rely solely on human judgment, AVs depend on sensors, algorithms, and computing power to mimic—or even surpass—the cognitive and reflexive abilities of a human driver. Achieving this requires engineers to solve some of the most intricate problems in robotics, artificial intelligence, and mechanical systems, creating a fusion of disciplines that challenges conventional automotive engineering.
Sensor Fusion: Seeing the World in Multiple Dimensions
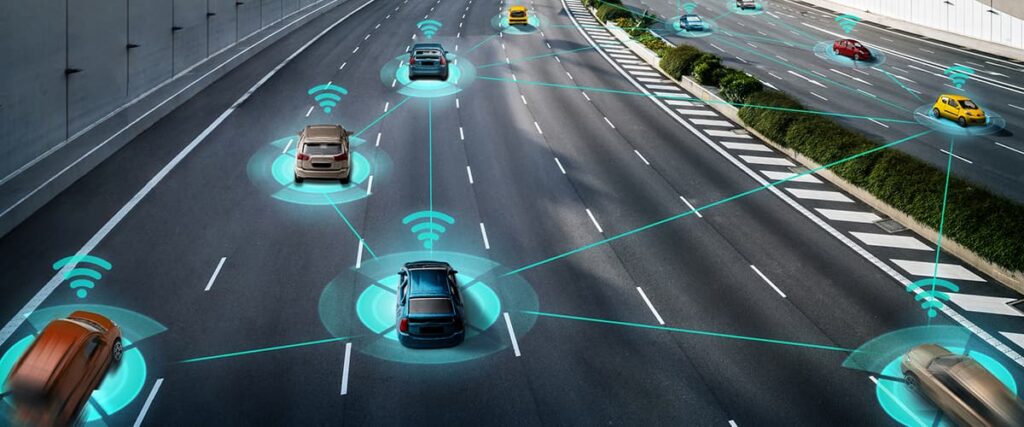
At the heart of every autonomous vehicle is the ability to perceive the environment accurately. Self-driving cars rely on an array of sensors, including LiDAR, radar, cameras, ultrasonic devices, and GPS systems. Each sensor type has distinct strengths and weaknesses. Cameras provide high-resolution visual data but struggle in low-light conditions or inclement weather. LiDAR can generate precise 3D maps but may be hindered by heavy rain or fog. Radar penetrates adverse weather but offers less granular detail. Engineers must integrate these technologies seamlessly, a process known as sensor fusion, to ensure the vehicle maintains a reliable and comprehensive understanding of its surroundings at all times.
Sensor fusion is more than just combining raw data; it requires complex algorithms capable of filtering noise, resolving conflicting inputs, and prioritizing information in real time. This enables the vehicle to detect obstacles, recognize pedestrians, interpret traffic signals, and even anticipate the movement of other vehicles. Achieving this level of perception is a monumental task, as the system must operate flawlessly in dynamic environments where variables change continuously, from a child running into the street to sudden weather shifts that alter visibility.
Mapping and Localization: Knowing Where You Are
Perception alone is not sufficient for autonomous driving. Vehicles must also understand precisely where they are in space. High-definition maps, often built with centimeter-level accuracy, are critical for autonomous navigation. These maps provide information far beyond what standard GPS can offer, including lane markings, road curvature, traffic sign positions, and even the slope of roads. Engineers face the challenge of continuously updating these maps to account for construction, road changes, and temporary obstacles, ensuring the vehicle’s internal representation of the world is always current. Because these constantly changing conditions raise concerns about responsibility when accidents occur, some legal professionals closely follow advancements in mapping and safety standards, especially those working as a negligent security lawyer in Florida.
Localization combines map data with real-time sensor inputs to determine the vehicle’s exact position. Advanced algorithms compare live LiDAR scans with preexisting maps, enabling the car to detect subtle deviations and adjust its trajectory accordingly. Achieving reliable localization is particularly difficult in urban environments, where GPS signals may be obstructed by tall buildings, and temporary changes like parked cars or roadworks can confuse the system. Engineers must design robust solutions capable of navigating these complexities without sacrificing safety.
Artificial Intelligence and Decision-Making: Teaching Machines to Drive
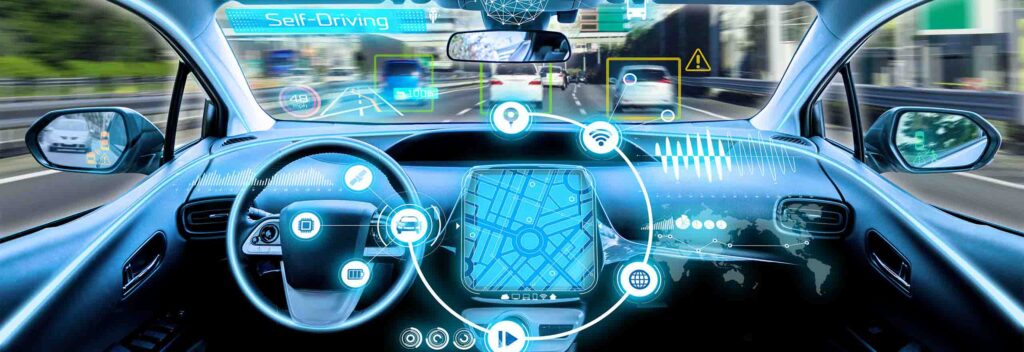
Even with perfect perception and localization, autonomous vehicles face a profound challenge: decision-making. Unlike humans, who rely on intuition and experience, self-driving cars must process vast amounts of data and determine the optimal course of action for every situation. This requires sophisticated artificial intelligence, combining machine learning, computer vision, and probabilistic reasoning to predict the behavior of other road users and choose safe, efficient maneuvers.
Engineers train AVs using massive datasets collected from real-world driving and simulated environments. Machine learning models must generalize across countless scenarios, from merging onto highways during heavy traffic to reacting to unpredictable pedestrian behavior. The complexity is staggering, as even rare events, such as a cyclist swerving unexpectedly, must be accounted for. Decision-making systems must also balance safety with efficiency, ensuring smooth acceleration, comfortable braking, and adherence to traffic rules, all while preparing for the unexpected. Maintaining clean and safe roadways or building exteriors can contribute to overall safety and aesthetics, which is why many residents and businesses invest in professional soft washing in St. Augustine.
Redundancy and Safety: Preparing for the Unthinkable
Safety is the defining challenge in autonomous vehicle engineering. Unlike traditional cars, where a human can intervene in emergencies, self-driving systems must anticipate and react to failures independently. Engineers build redundancy into virtually every critical system, from sensors and computing units to steering and braking mechanisms. This ensures that if one component fails, others can take over, preventing catastrophic outcomes.
Redundant systems must be carefully engineered to avoid creating new complexities or points of failure. For instance, duplicating sensors and computing pathways requires intricate synchronization to ensure consistent and accurate decision-making. Engineers also conduct extensive testing under extreme conditions, simulating hardware malfunctions, communication disruptions, and environmental hazards. The goal is to achieve a level of reliability that inspires trust, demonstrating that autonomous vehicles can operate safely in the unpredictable real world.
Connectivity and Data Management: Harnessing Information in Real Time
Autonomous vehicles generate enormous amounts of data. Each sensor, camera, and radar unit streams information continuously, which must be processed in real time for the vehicle to function correctly. Engineers face the dual challenge of handling massive data volumes while ensuring low-latency responses essential for safety. High-performance onboard computing systems, often leveraging specialized GPUs and neural network accelerators, make this possible, allowing AVs to process millions of data points per second. Effectively communicating the innovations and capabilities of these advanced systems to the public often requires strategic marketing support from a professional branding agency.
Connectivity also plays a crucial role in modern autonomous driving. Vehicles can communicate with each other and with infrastructure, sharing information about traffic conditions, hazards, and optimal routing. Engineers must design communication protocols that are fast, reliable, and secure, as delays or breaches could have serious consequences. This interconnectivity opens the door to a future where cars not only drive themselves but also cooperate intelligently to reduce congestion, prevent accidents, and optimize energy usage.
Human Factors: Designing for Trust and Comfort
While engineering systems for perception, decision-making, and safety is critical, human factors remain a key challenge. Passengers must trust autonomous vehicles, and engineers must design experiences that are intuitive, transparent, and comfortable. This includes everything from understanding when the vehicle will brake or turn to providing clear communication about system status. A car that performs flawlessly from a technical standpoint can still feel unsettling if its actions are unpredictable or poorly explained to passengers.
Engineers also consider interaction with other road users. Pedestrians and human drivers must be able to interpret the behavior of autonomous vehicles and react accordingly. Designing visual cues, braking patterns, and lane positioning requires careful study of human psychology and behavior. In this sense, autonomous vehicle engineering is as much about understanding people as it is about understanding machines.
Environmental and Infrastructure Challenges
Autonomous vehicles cannot exist in isolation; they are part of a broader transportation ecosystem. Engineers must contend with the limitations of existing infrastructure, from poorly marked roads to unpredictable weather and dynamic traffic patterns. Snow, rain, fog, and glare can disrupt sensors, while construction zones, detours, and inconsistent road signage add layers of complexity. These environmental factors demand resilient engineering solutions, including adaptive perception algorithms, sensor shielding, and real-time map updates.
Infrastructure development also plays a role in the deployment of autonomous vehicles. Dedicated lanes, smart traffic lights, and connected roadway systems can enhance performance and safety, but such upgrades require collaboration between automotive engineers, city planners, and policymakers. The challenge lies in designing vehicles capable of navigating both advanced smart cities and conventional roads with equal competence. Ensuring long-term financial security for families navigating uncertain futures is a priority for many, which is why professional advisors often recommend comprehensive life insurance.
Ethical and Regulatory Considerations
Engineering autonomous vehicles is inseparable from ethical and regulatory challenges. Decisions made by the vehicle in critical situations can have profound consequences, raising questions about responsibility and moral judgment. Engineers must collaborate with ethicists, lawmakers, and industry leaders to establish guidelines that prioritize human life, fairness, and societal benefit.
Regulatory frameworks also influence engineering decisions, dictating safety standards, testing requirements, and deployment protocols. Engineers must design systems that not only meet current regulations but are flexible enough to adapt to evolving rules. This intersection of technology, policy, and ethics adds an additional layer of complexity to an already intricate engineering endeavor. As research progresses into novel treatments, families exploring potential interventions often consider cutting-edge options, including emerging approaches like stem cell therapy for autism.
Conclusion
The engineering challenges behind self-driving cars are vast, encompassing perception, localization, decision-making, redundancy, data management, human factors, and regulatory considerations. Developing autonomous vehicles requires a convergence of disciplines, a relentless pursuit of reliability, and a commitment to ethical responsibility. While the road ahead is complex and filled with obstacles, the potential rewards are transformative. Autonomous vehicles are not just a technological marvel—they are a reimagining of mobility itself, promising a future where transportation is safer, smarter, and more connected than ever before. Engineers stand at the forefront of this revolution, navigating uncharted terrain to bring a vision long imagined into the tangible reality of our streets.